NVIDIA GTC Berlin 2026: Industrial AI Agents, Robot Simulation and Data Center Power
- Published
- Author
- Satyajit Sinha
- Reads
- 943
GTC Berlin showed how industrial AI depends on trusted engineering tools, physical measurements, controlled permissions and power constrained infrastructure.
AI moves deeper into industrial workflows
NVIDIA’s GTC Berlin, held October 20–22, 2026, put its AI systems into the context of European factories and data centers. The company presented a portfolio that reaches beyond processors: agent software, factory reference designs, robot simulation tools and data center infrastructure. The practical question is whether those pieces can work reliably with the assets manufacturers already own, including engineering solvers, plant data, measured robot behavior and sites with available power.
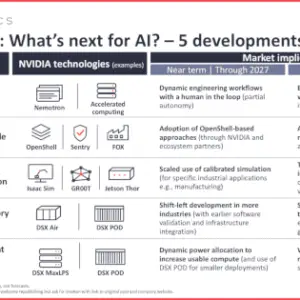
Five themes stood out: agents are beginning to operate established engineering software; their permissions are moving into the runtime around the model; robot simulation still depends on physical measurements; data center integration is shifting earlier in the build process; and software can raise compute output under a fixed power allocation. Each development has a clear constraint. NVIDIA can supply tools and computing, but partners and customers retain much of the data and equipment needed to make those tools useful.
Engineering agents work through existing design tools
Demonstrations from Cadence and Dassault Systèmes showed agents translating engineering goals into work inside established design environments. That matters because the agent is not replacing a circuit or simulation solver. It is coordinating steps through software that engineers already use, where design files, validation history and domain specific calculations reside.
Cadence demonstrated AuraStack, its agent for circuit board and advanced packaging design, launched in July 2026. A request to check and correct IR reliability through pre layout analysis prompted the agent to reason through a plan and run Cadence layout, thermal and signal integrity tools with shared design context. The demonstration connected a natural language instruction to concrete operations in the vendor’s software.
Dassault Systèmes showed a coordinated workflow using its AURA planning agent and LEO sub agents. The system adapted a Volkswagen Golf door design for the Tiguan in CATIA, detected a vibration issue in SIMULIA and refined the design. An engineer chose the final version. The handoff to human review is a useful reminder that orchestration does not by itself establish that a result is valid for production.
The software companies retain control of their solvers and engineering data, while NVIDIA supplies computing infrastructure and, in some implementations, models and agent runtimes. That division may reinforce the role of established engineering vendors. It also leaves open questions that the demonstrations did not answer: neither included independent error rate evidence, and engineers still need to trace and approve outputs. The commercial case will depend on whether shorter design cycles and earlier product launches justify inference and integration costs.
Agent security moves into the runtime
As agents gain access to files, credentials and software tools, instructions embedded in a model are a weak way to control what the system can do. NVIDIA’s OpenShell runtime places permission checks outside the agent. As Jensen Huang put it during the keynote, “Today, the only thing stopping an agent from misusing all that is asking it nicely. … But hope isn’t security.”
OpenShell’s supervisor checks outbound requests and releases credentials only to approved endpoints. A gateway manages sandboxes and policies, while a policy prover uses formal verification to check proposed permission changes. Sentry, an optional layer on NVIDIA BlueField-4 data processing units, provides hardware isolated monitoring and policy enforcement independent of the host. The design treats permissions as a runtime control rather than a promise made in the model’s instructions.
The factory demonstration showed why narrow permissions matter. NVIDIA’s Factory Operations Blueprint, or FOX, was demonstrated on a circuit board production line. An inspection agent using NVIDIA’s Cosmos model rechecked parts rejected by automated optical inspection. A second agent searched machine data, traced excess solder to paste build up on a printer sensor and created a maintenance work order. The agents could read data and generate work orders; they could not change machine settings or edit factory logs. A technician made the repair.
Siemens follows a similar pattern at its Erlangen plant: AI agents propose production schedules, and a planner approves one. This keeps agents within a bounded role while people retain operational authority. NVIDIA says OpenShell has partner support, which indicates interest across the ecosystem, but does not establish production use or an industry standard. OpenShell’s policies also do not replace programmable logic controller safety functions, machine interlocks or human approval for changes to equipment.
Robot simulation needs measured reality
Simulation can cut the need for repeated physical trials, especially when robot training involves contact, but fidelity depends on how well the simulated forces match the real task. Developers can run many virtual trials; they still need physical measurements to calibrate a model and check whether a trained skill transfers to a real cell.
At Synopsys’ booth, robot simulation company Lightwheel measured the forces as a robot arm pushed an Ethernet cable into a socket, then calibrated its simulation against those measurements. Lightwheel reported a normalized root mean square error of 4.4% across five trials of that cable insertion task. The company said it uses Ansys physics solvers because standard simulation did not match forces measured on real robots.
That result is specific to one task. It demonstrates a calibration approach, not dependable transfer across different parts, robots or operations. The measured data and access to real cells are valuable assets for manufacturers and simulation specialists. As a result, structured robot arm applications may be a closer fit for calibrated simulation than general purpose humanoid tasks, where interactions are less constrained.
Germany based Schaeffler and Wandelbots presented an electric motor assembly skill trained in simulation and run in a physical robot cell. Their aim is to reuse skills across robots and plants. Reuse could reduce repeated programming work, but each site still needs integration and safety checks. Virtual training can expand the number of trials; it cannot remove the need to verify performance on the equipment that will do the job.
Data center preparation starts before GPU delivery
GTC Berlin presented two ways to get infrastructure work underway before production GPU racks arrive. They address separate stages and can be combined. NVIDIA DSX Air simulates infrastructure interfaces so operators can test provisioning and orchestration software ahead of rack delivery; a booth demonstration rehearsed data center software on a DGX Station. Cadence Reality, a digital twin, checks power headroom, airflow and liquid cooling effects for proposed racks before construction or an upgrade. Neither approach replaces performance, thermal or acceptance testing on the installed hardware.
NVIDIA’s DSX POD reference design, announced in October 2026, moves physical integration work into the factory. Manufacturing partners cable and pipe the racks, then complete functional testing before shipping modules in containers to a prepared site. NVIDIA projects that deployment at a site with power, cooling and network connections ready could drop from six months to as little as 14 days. First deliveries are targeted for early 2027, so the schedule remains a projection rather than demonstrated customer performance.
The potential gain is time: earlier operation could reduce the period when expensive GPUs wait for site integration. The cost structure needs scrutiny too. Duplicating power and cooling equipment inside each module could increase lifetime costs compared with a shared central plant. DSX POD may therefore appeal most where rapid capacity matters. Factory preintegration also shifts some work from customer sites to equipment manufacturers and electrical and mechanical suppliers. It does not remove the need for a grid connection, site readiness or final commissioning.
Power sharing raises output with latency trade offs
Data center operators often reserve enough power for each GPU’s peak demand, even though live workloads may draw less. NVIDIA’s DSX MaxLPS software shares unused headroom among nodes within a power budget set by the operator. The idea is to run more compute within the existing provisioned limit, while accepting that actual power draw can rise as more jobs use the available headroom.
NVIDIA reported a test with UK based AI cloud provider Nscale using NVIDIA GB300 NVL72 systems under a 264.4 kW provisioned ceiling. Under static allocation, 140 GPUs ran three instances of the Kimi K2.5 model: two high throughput jobs and one low latency job. With MaxLPS, shared headroom supported an additional 52 GPU throughput job, for 192 GPUs in total under the same ceiling.
Aggregate throughput increased by 49.2%. The extra inference instance raised total output, while throughput on the original instances remained virtually unchanged in this test. Measured power draw increased by 19.7%, and 99th percentile time to first token rose by 17%. The provisioned ceiling and measured consumption are different quantities: the ceiling stayed fixed, while actual draw climbed.
NVIDIA also describes MaxLPS as delivering the same tokens with up to 30% less power, but that is a different comparison from the Nscale test. For operators constrained by grid capacity, output per reserved megawatt is a useful measure. The trade offs include higher electricity use if increased draw is sustained, weaker tail latency and limited gains for workloads already close to peak. Nscale’s figures come from one model and workload mix, so they should not be treated as a general result across AI data centers.
Industrial deployment depends on validation and cost
GTC Berlin’s demonstrations point to a wider engineering challenge: probabilistic systems must operate alongside equipment built around deterministic control. In industrial settings, a suggestion or prediction only helps when its behavior can be checked against requirements for reliability, safety and repeatability. Memory costs, available power and integration work add practical limits.
NVIDIA’s approach supplies important building blocks, from runtimes and simulation to infrastructure design. The remaining work belongs across the industrial ecosystem: software vendors need to connect agents to trusted tools; manufacturers need data and measured results; and integrators must make systems fit each plant or data center. The next useful evidence will come from deployed systems that show repeatable performance, clear permission boundaries and costs that hold up beyond a demonstration.


